
You can check the previous projects here.
Terrain-Adaptive Robotic Foot Using Negative Stiffness Structure
Section: Robotics, Mechanical Engineering, Microengineering
Supervisors: Dr. Hwayeong Jeong and Prof. Jamie Paik
Number of Credits: 10 ECTS (300 hours)
Type: 60% Mechanical Design and Testing, 20% Control, 20% Evaluation
Requirements: Mechanical design and prototyping (3D printing), CAD modeling, and basic experimental analysis skills. Experience with origami structures, compliant mechanisms, robot control, or granular materials is a plus.
Description:
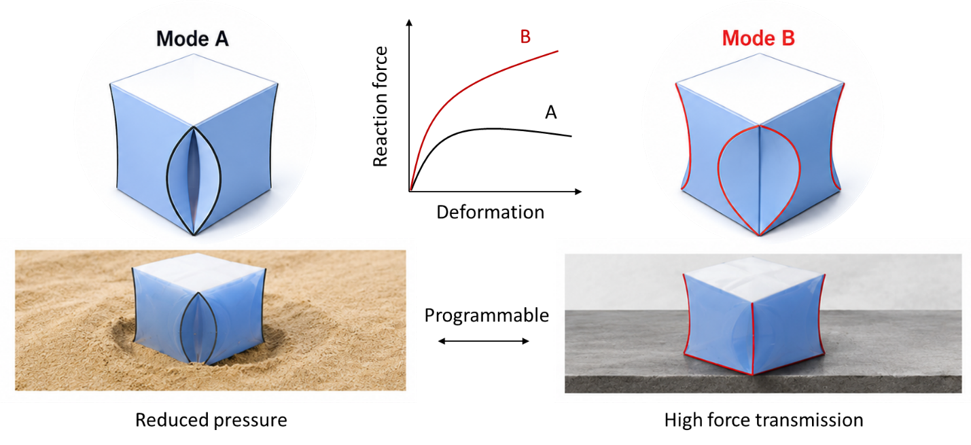
Legged robots are expected to operate on terrains with widely different mechanical properties. On rigid ground, a robotic foot should remain stiff to efficiently transmit actuator forces during stance and push-off. On deformable terrain such as sand, however, a compact rigid foot may sink, slip, and lose energy by displacing the surrounding material.
This project aims to develop a terrain-adaptive robotic foot using curved-origami structures with programmable stiffness (negative and positive stiffness). Curved origami can combine panel bending and crease folding to generate positive, quasi-zero, and negative stiffness responses. By selecting the crease geometry and structural configuration, the same mechanism can provide either a stiff load-bearing response or a compliant snap-through transition.
The proposed foot will use this behavior to switch between two configurations. On rigid surfaces, the foot should remain compact and stiff to provide efficient force transmission. On sand, compression of the foot should trigger a curved-origami mechanism that expands the effective contact area, distributes the load, and reduces excessive sinkage. Following deployment, a mechanical stop or locking mechanism should provide sufficient stiffness for stable support and push-off.
Through this project, the student is expected to develop expertise in curved-origami design, compliant and variable-stiffness mechanisms, robotic foot development, experimental characterization, and scientific paper writing. The lab will provide access to robotic hardware, rapid prototyping facilities, force and displacement sensors, granular-terrain test setups, and training in origami fabrication and experimental testing.
Expected Work:
- Review curved origami, negative stiffness mechanisms, robotic feet, and locomotion on granular terrain.
- Analyze the mechanical requirements of a terrain-adaptive foot, including size, weight, load capacity, stiffness, deployment displacement, and integration constraints.
- Develop and compare curved-origami concepts capable of switching between a compact stiff configuration and an expanded load-bearing configuration.
- Model the force-displacement response and investigate the effects of crease curvature, panel stiffness, geometry, and mechanical constraints.
- Design and fabricate a selected foot mechanism using CAD and rapid prototyping methods.
- Integrate mechanical stops, latches, sensing, or actuation where required.
- Develop a basic control or switching strategy for selecting the appropriate foot configuration.
- Establish evaluation metrics and experimentally compare the adaptive foot with a conventional rigid foot on rigid and granular surfaces.
- Evaluate performance in terms of sink depth, contact area, slip, load-bearing capability, push-off force, extraction force, mechanical work, repeatability, and durability.
Contact: [email protected]