
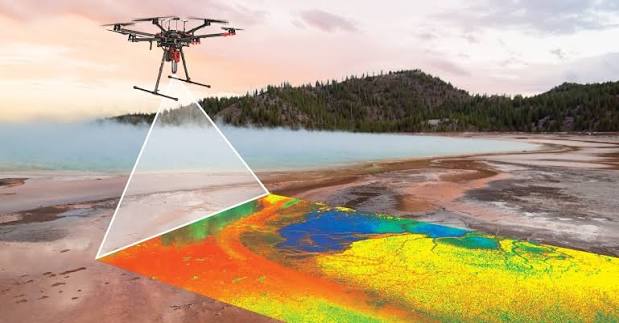
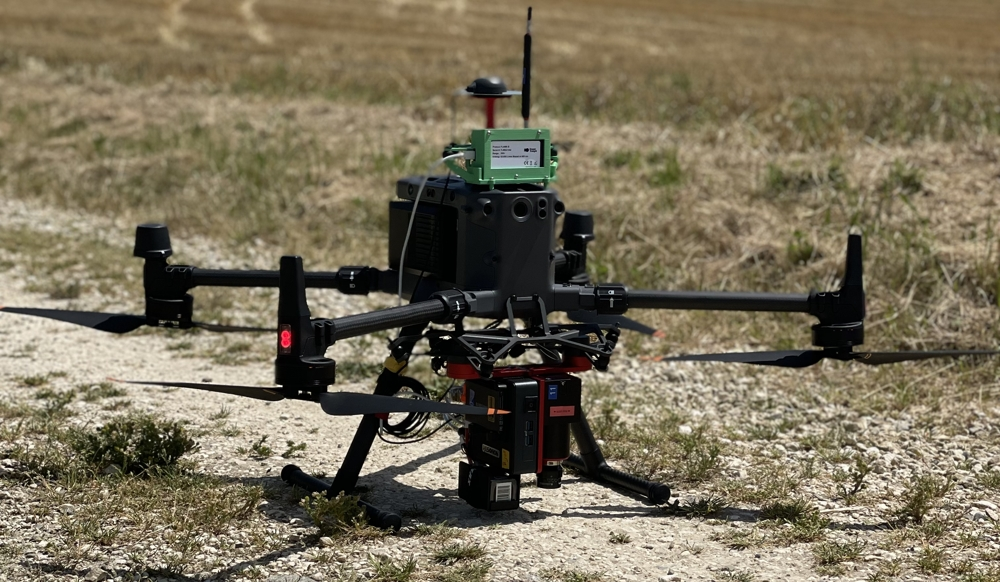
Hyperspectral cameras are used to produce remote sensing data for snow cap monitoring, forests management and other important field. They can reveal hidden information not available by using just light in the visual spectrum. But they tend to be heavier than RGB cameras, and since they acquire a single line of pixel at a time, are reliant on accurate georeferencing information to build usable orthoimages from the acquisition data.
The Resonon PikaL is a minature hyperspectral camera, designed to be deployed a payload on UAV. The goal of this project is to improve the acquisition firmware to :
- ensure accurate synchronization between exposition frames from the camera, and the navigation computer of the platform used for flight.
- possibly allow the camera to be flown with a smaller processing computer, and direct integration with the drone navigation system, increasing the payload capacity of the platform for other sensors.
Task Description and Methodology
Inputs:
- Pika-L camera
- DJI Integration SDK package
- DJI-M350 for development and flight testing
Deliverables:
- Report summarizing solution design and usage
- Integrated circuit board and embedded-PC implementation to manage the camera synchronization
- Code implementation of new firmware published to lab GitLab account
Prerequisites
- Experience with low level hardware programming (c or c++), linux driver programming, notions of electrical engineering, Computer Vision.
References
Contact
Interested candidates are kindly asked to send us by email their CV/github profile and a short motivation statement.
Simon Gilgien Laurent Jospin