
Outline
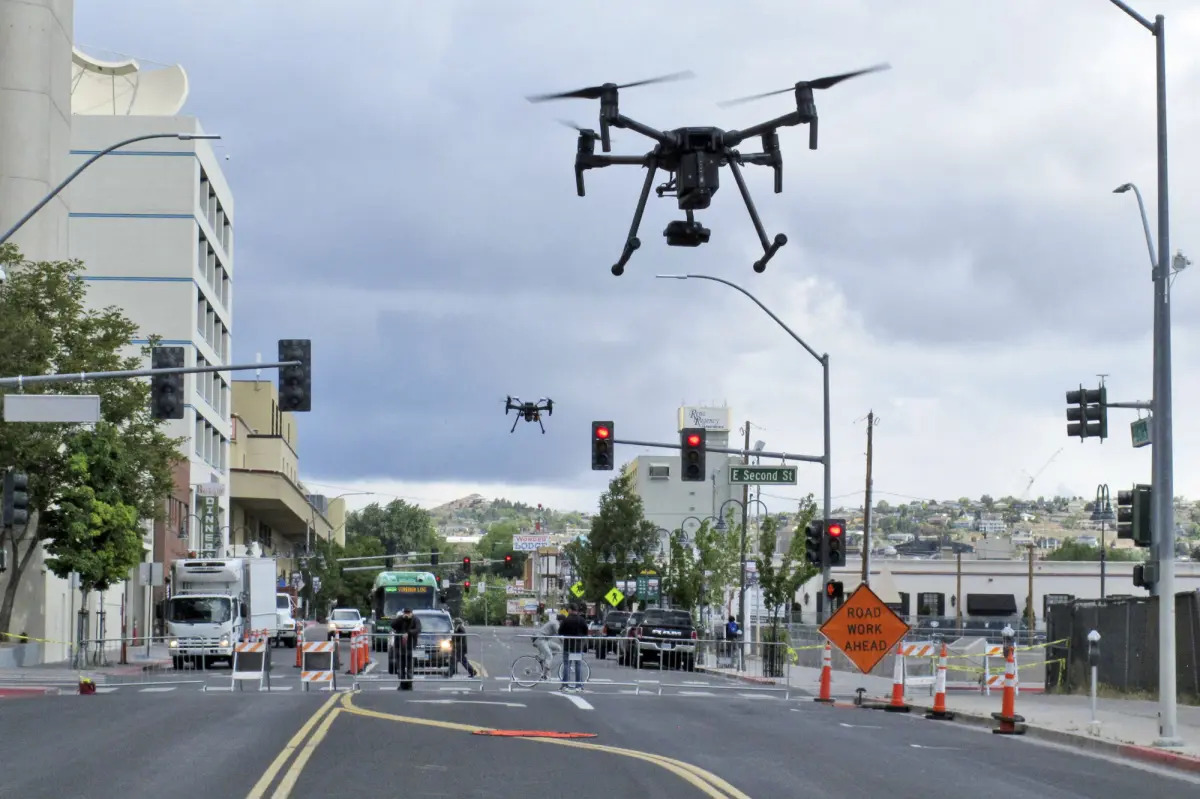
This project aims to develop an efficient, scalable control framework for a fleet of autonomous quadrotors (e.g., Crazyflies) tasked with real-time traffic monitoring and urban surveillance. The project will bridge the gap between high-level multi-agent coordination and low-level physical execution by exploring two core control layers:
- Reinforcement Learning: Developed in simulation to optimize high-level fleet routing and adaptive traffic monitoring while avoiding collisions with other drones based on dynamic priority levels.
- Model Predictive Control: Implemented on the physical drone hardware to ensure high-precision trajectory tracking and success demonstration in a laboratory setup.
Tentative milestones
- Weeks 1–2: Multi-drone hardware interface setup (ROS 2, Crazyradio integration) and initialization of the multi-agent simulation environment.
- Weeks 3–4: Design of the traffic monitoring simulation scenarios; baseline single-drone tracking and communication validation.
- Weeks 5–10: Core development phase: Training reinforcement learning policies for multi-agent fleet behavior in simulation while concurrently designing the MPC controller for trajectory tracking.
- Weeks 11–14: Hardware-in-the-loop testing and live experimental demonstration of the fleet; evaluation of tracking accuracy and coverage robustness.
Requirements
- Proficient in Python; independent troubleshooting skills.
- Hands-on experience with ROS 2 and real-world drone (e.g., Crazyflies) experiments.
- Solid theoretical foundational knowledge of Reinforcement Learning and Control Theory (particularly MPC).
To Apply
Please email (1) a short paragraph describing your background and motivation, and (2) your CV and academic transcripts to: [email protected] and [email protected]
References
[1] Nguyen, Khai, et al. “Tinympc: Model-predictive control on resource-constrained microcontrollers.” 2024 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2024.
[2] Prajapat, Manish, et al. “Submodular reinforcement learning.” International Conference on Learning Representations. Vol. 2024. 2024.
[3] Chen, Wenjing, et al. “Multi-Agent Reinforcement Learning with Submodular Reward.” arXiv preprint arXiv:2603.06810 (2026).
[4] C. Llanes, Z. Kakish, K. Williams, and S. Coogan, “CrazySim: A Software-in-the-Loop Simulator for the Crazyflie Nano Quadrotor,” To appear in 2024 IEEE International Conference on Robotics and Automation (ICRA), 2024.
GitHub: https://github.com/llanesc/crazyflie-mpc-example